

NoDrift3R: Raymap-Guided Coupling for Drift-Robust Unposed Feed-Forward 3D Reconstruction
Paper • 2607.07168 • Published • 1
Project Page | Paper | Code
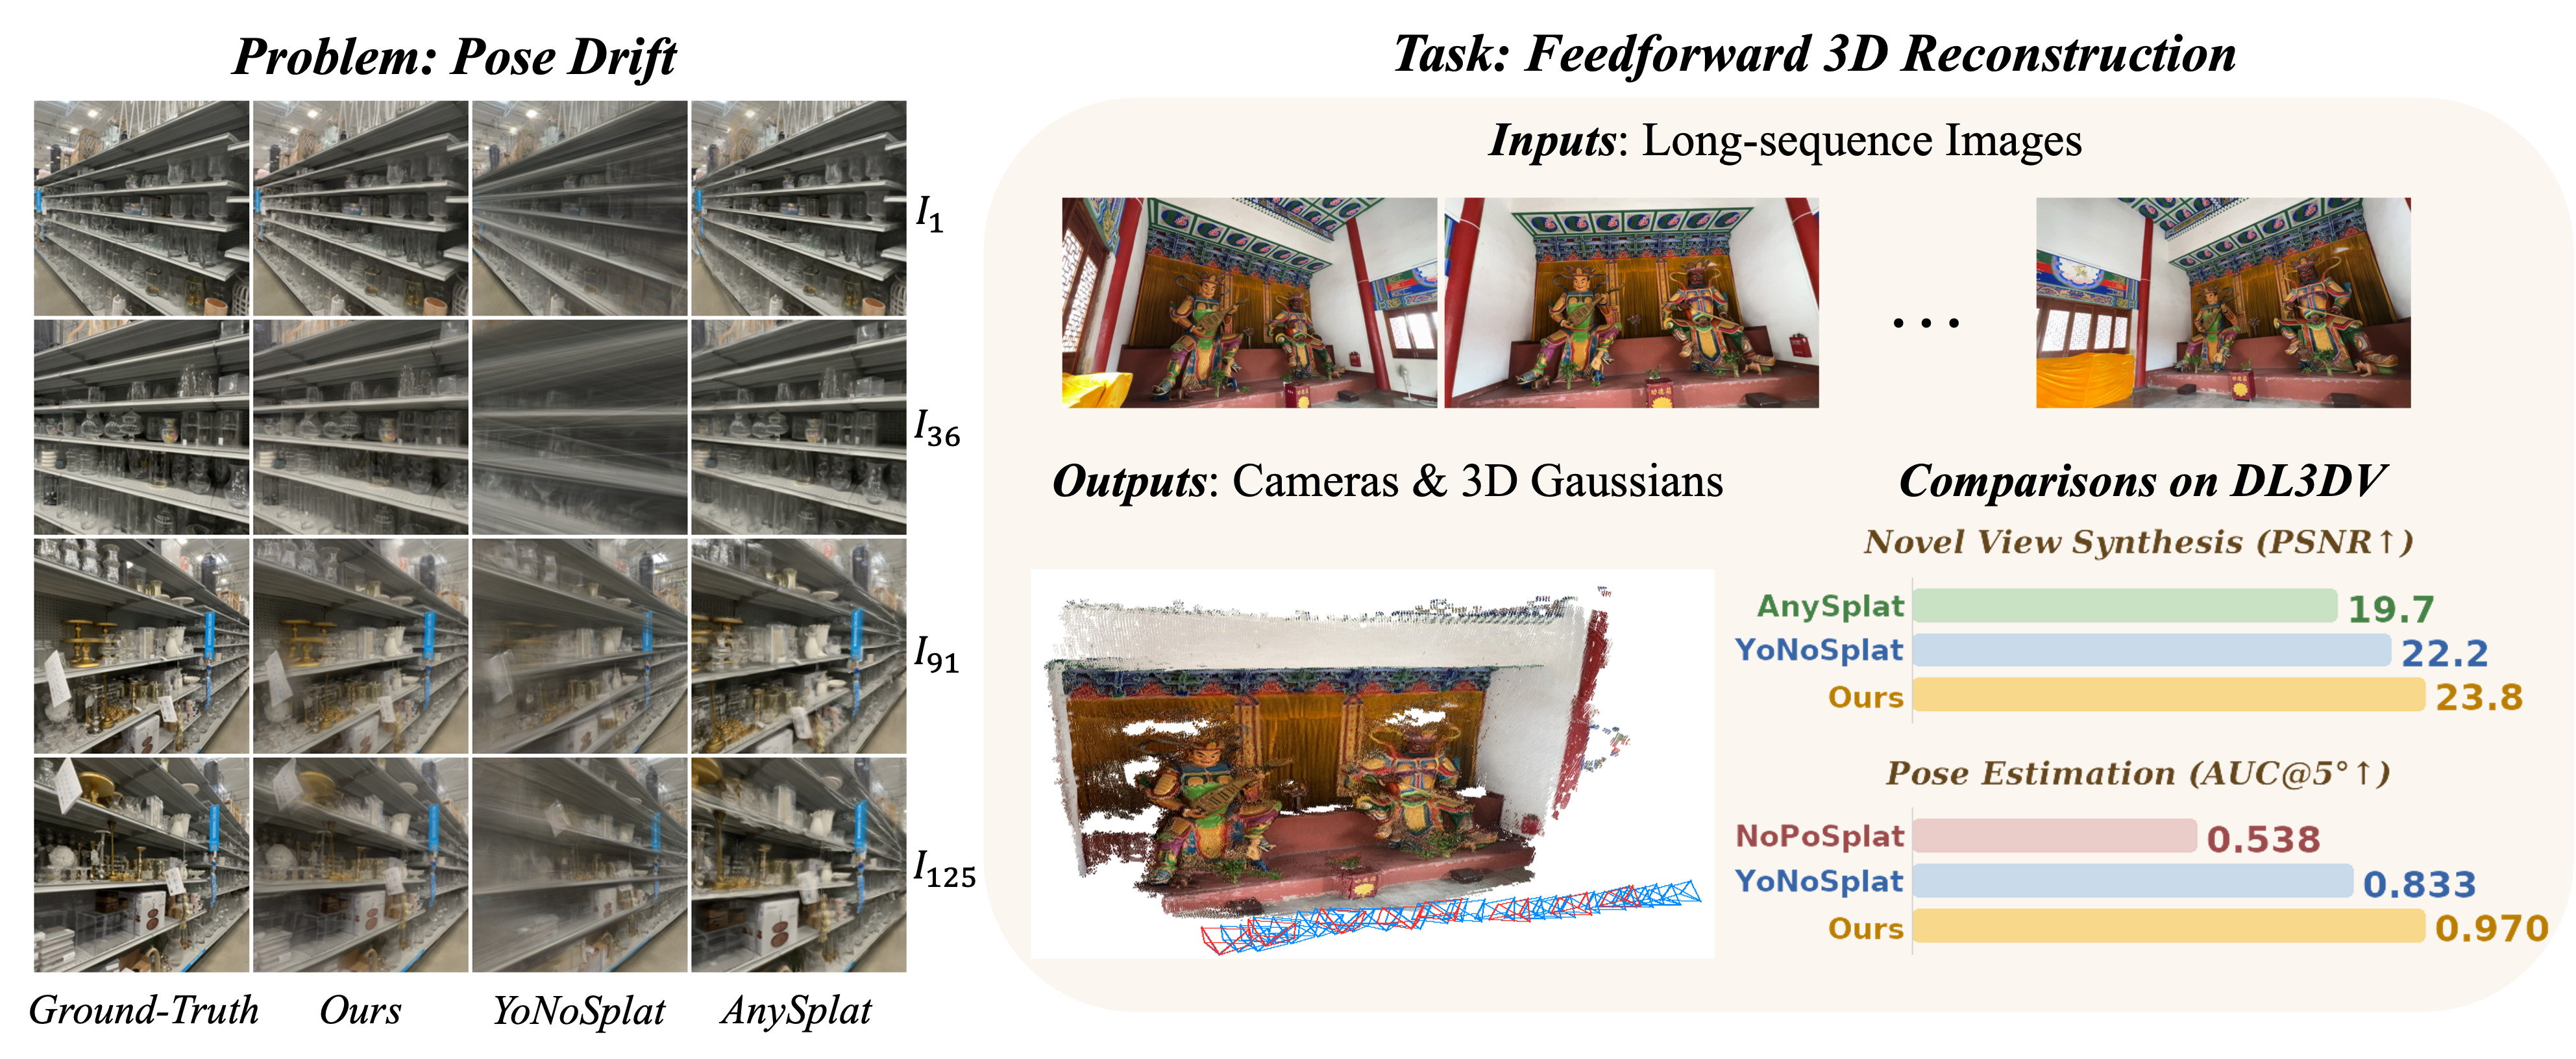
NoDrift3R is an ECCV 2026 method for drift-robust, pose-free feed-forward 3D Gaussian Splatting reconstruction. It targets cumulative camera-pose drift in long, unposed image sequences by explicitly coupling geometry and appearance. Gaussian centers are anchored to raymap-induced geometry, while RGB reconstruction, raymap consistency, and camera regularization are optimized jointly to improve rendering, geometry, and pose estimation together.
This repository contains the following checkpoints:
dl3dv_giant_2_8_H20.ckptdl3dv_large_4_8_5090.ckptmix_dataset_giant_4_8_H20.ckptmix_dataset_large_8_8_5090.ckptPlease follow the GitHub repository and project page for code, configuration, dataset, and usage updates.
The root config.yaml lists the released checkpoints with their file sizes
and SHA256 digests. Include it when selecting a checkpoint to download:
from huggingface_hub import snapshot_download

checkpoint = "dl3dv_large_4_8_5090.ckpt"
model_dir = snapshot_download(
    "HorizonRobotics/NoDrift3R",
    allow_patterns=["config.yaml", checkpoint],
    local_dir="NoDrift3R",
)
Choose any checkpoint listed above and follow the NoDrift3R code for loading and inference configuration.
If you find NoDrift3R useful in your research, please cite:
@misc{sun2026nodrift3rraymapguidedcouplingdriftrobust,
  title         = {NoDrift3R: Raymap-Guided Coupling for Drift-Robust Unposed Feed-Forward 3D Reconstruction},
  author        = {Xiangyu Sun and Liu Liu and Seungkwon Yang and Jingbing Han and Seungtae Nam and Zhizhong Su and Eunbyung Park},
  year          = {2026},
  eprint        = {2607.07168},
  archivePrefix = {arXiv},
  primaryClass  = {cs.CV},
  url           = {https://arxiv.org/abs/2607.07168}
}